

Engineered for Intelligent Indoor Automation
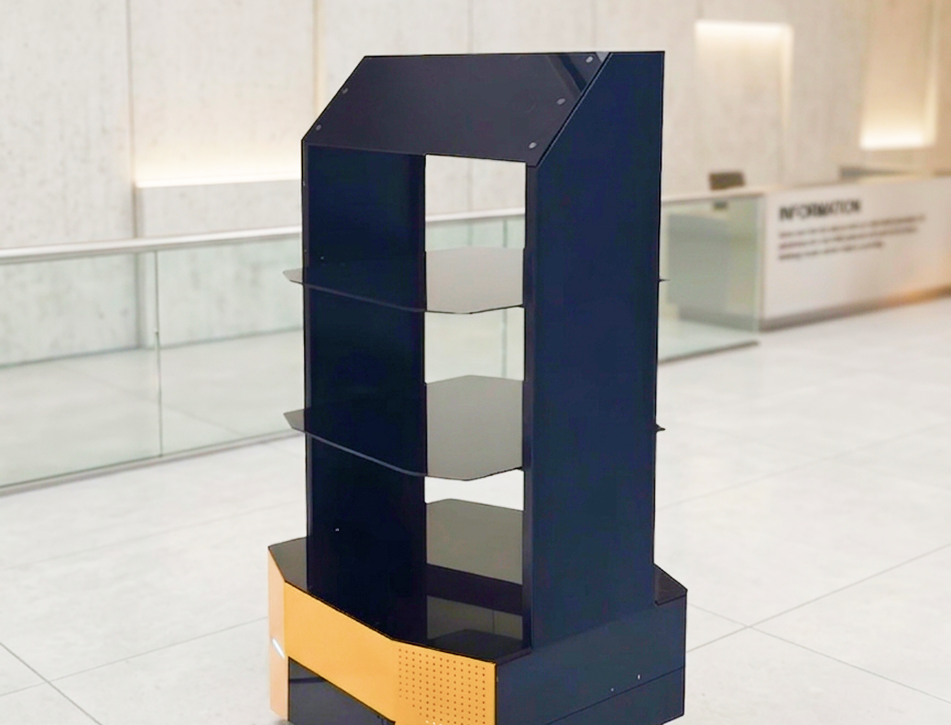
Deploy advanced Indoor AMR Differential Drive Platforms designed for precision navigation, AI-driven perception, and seamless autonomous operations in controlled environments.
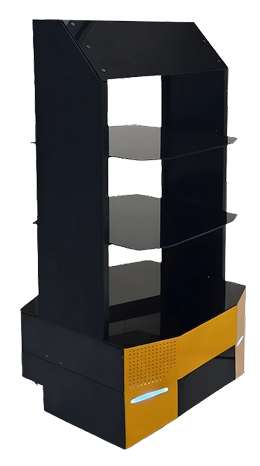
Indoor AMR – Differential Drive Research Platform
The Indoor Differential Drive AMR is a research-focused autonomous mobile platform built specifically for controlled indoor environments. Its differential drive system enables highly accurate motion control, smooth turning, and repeatable navigation—making it ideal for robotics research and AI experimentation.
Designed for flexibility, the platform supports advanced perception systems, sensor fusion workflows, and modular payload configurations. It empowers teams to rapidly move from manual control to fully autonomous operations.
Key Features

All-Terrain Indoor Stability
Optimized industrial-grade wheels ensure smooth movement across indoor surfaces with maximum stability.

Modular Build Architecture
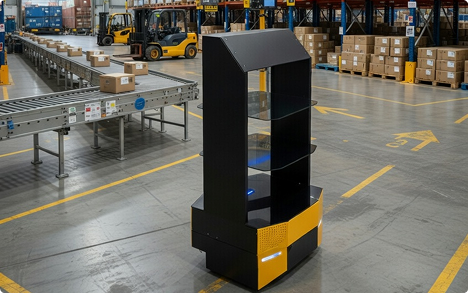
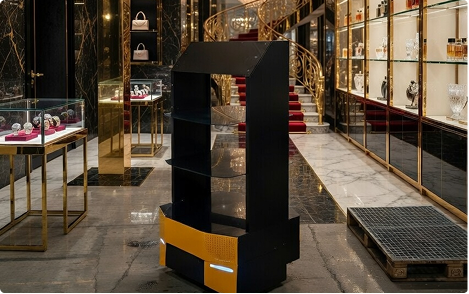
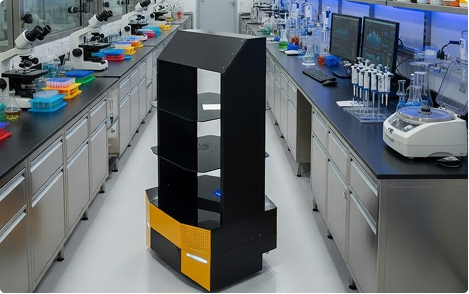
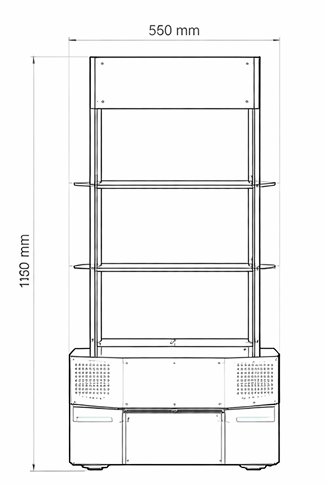
Three-layer stackable payload design for flexible hardware integration.

Differential Drive Precision
Accurate motion control with smooth turning and repeatable navigation paths.

High-Performance AI Computing
Built to efficiently process real-time perception tasks and support advanced AI workloads for reliable autonomous performance.

Autonomous Ready
Supports LiDAR, cameras, and sensor fusion systems for advanced AI navigation.

Flexible Operation Modes
Supports both manual RC control and fully autonomous workflows, offering flexibility for testing and deployment..
Tech Specs
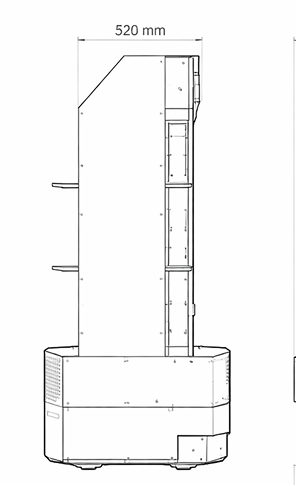
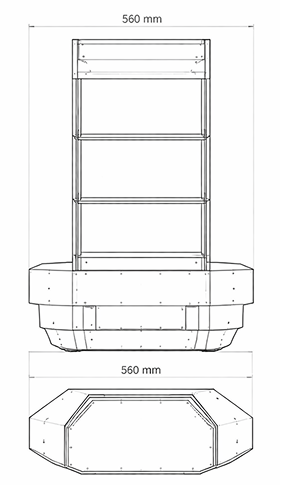
Navigation
Vision-based + Marker-based + SLAM Support
Build Type
Industrial-grade indoor platform
Control Modes
Manual (RC) + Autonomous
Architecture
Modular 3-Layer Stackable Design
Processing
High-efficiency AI computing compatible
Safety System
Emergency Stop + Obstacle Avoidance Support
Mobility Performance
High-precision movement with smooth turning radius
Software Compatibility
ROS / ROS2 Ready Architecture
Accessories
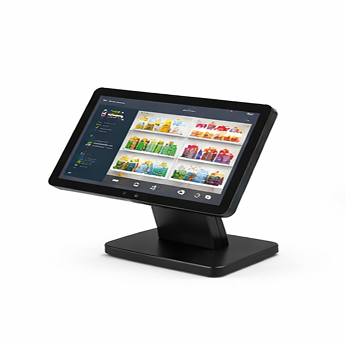
LED Status Indicators
Displays system status and operational
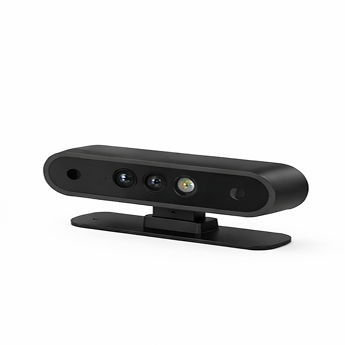
Vision Camera Module
Real-time visual perception for detection
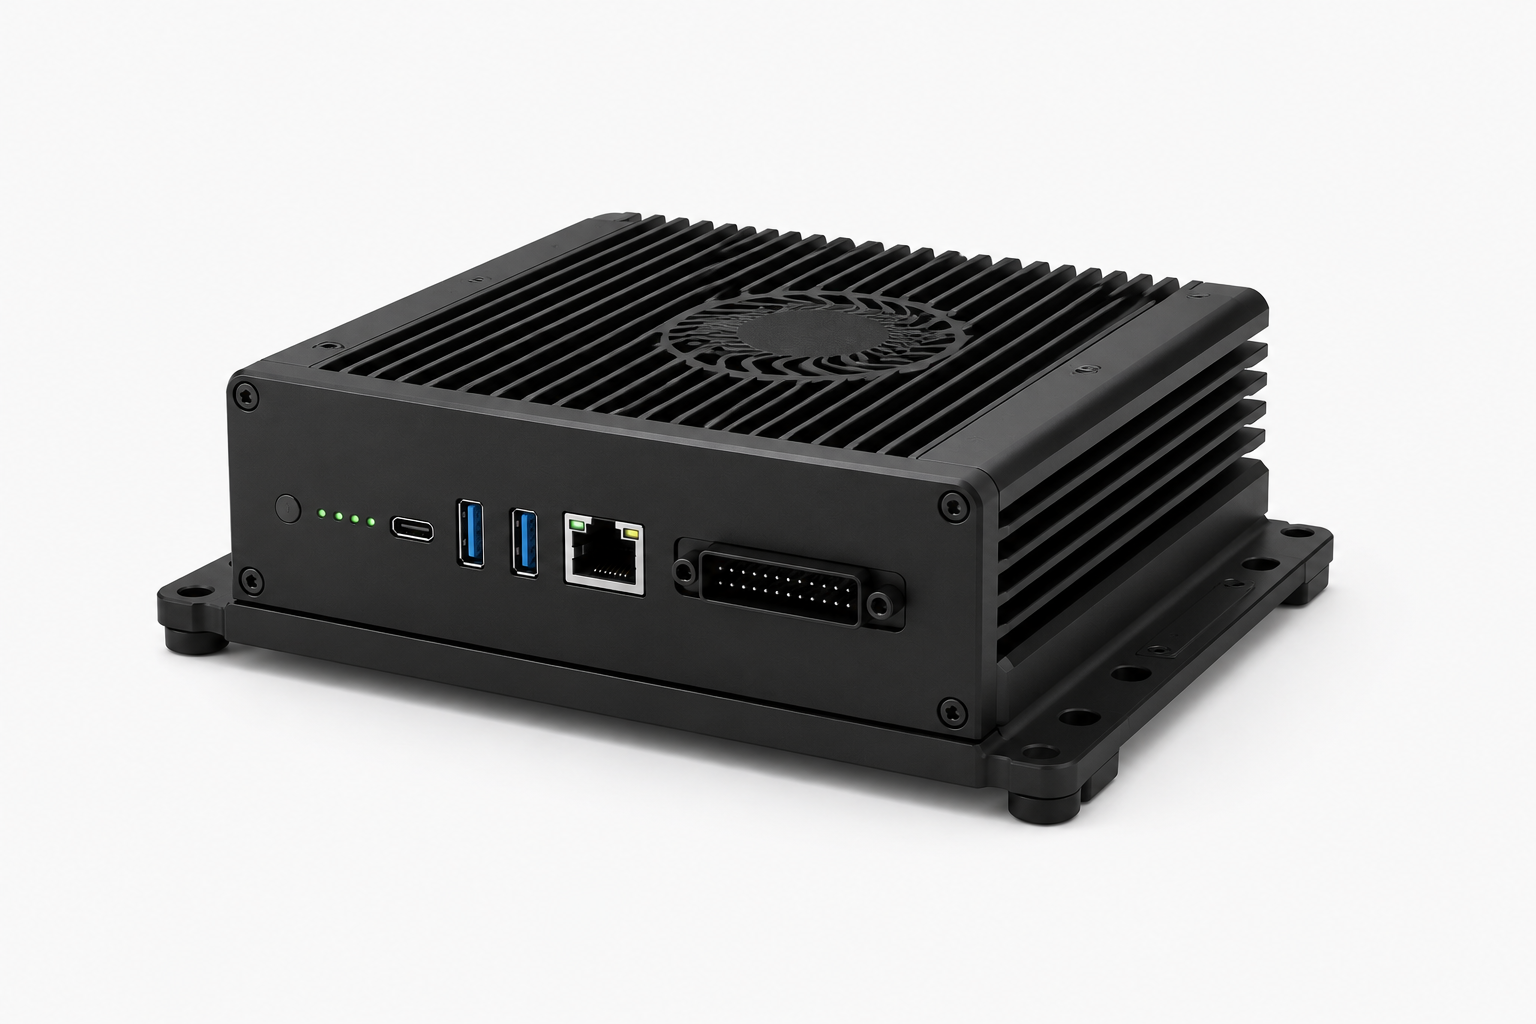
AI Compute Expansion Unit
Boosts processing power for AI
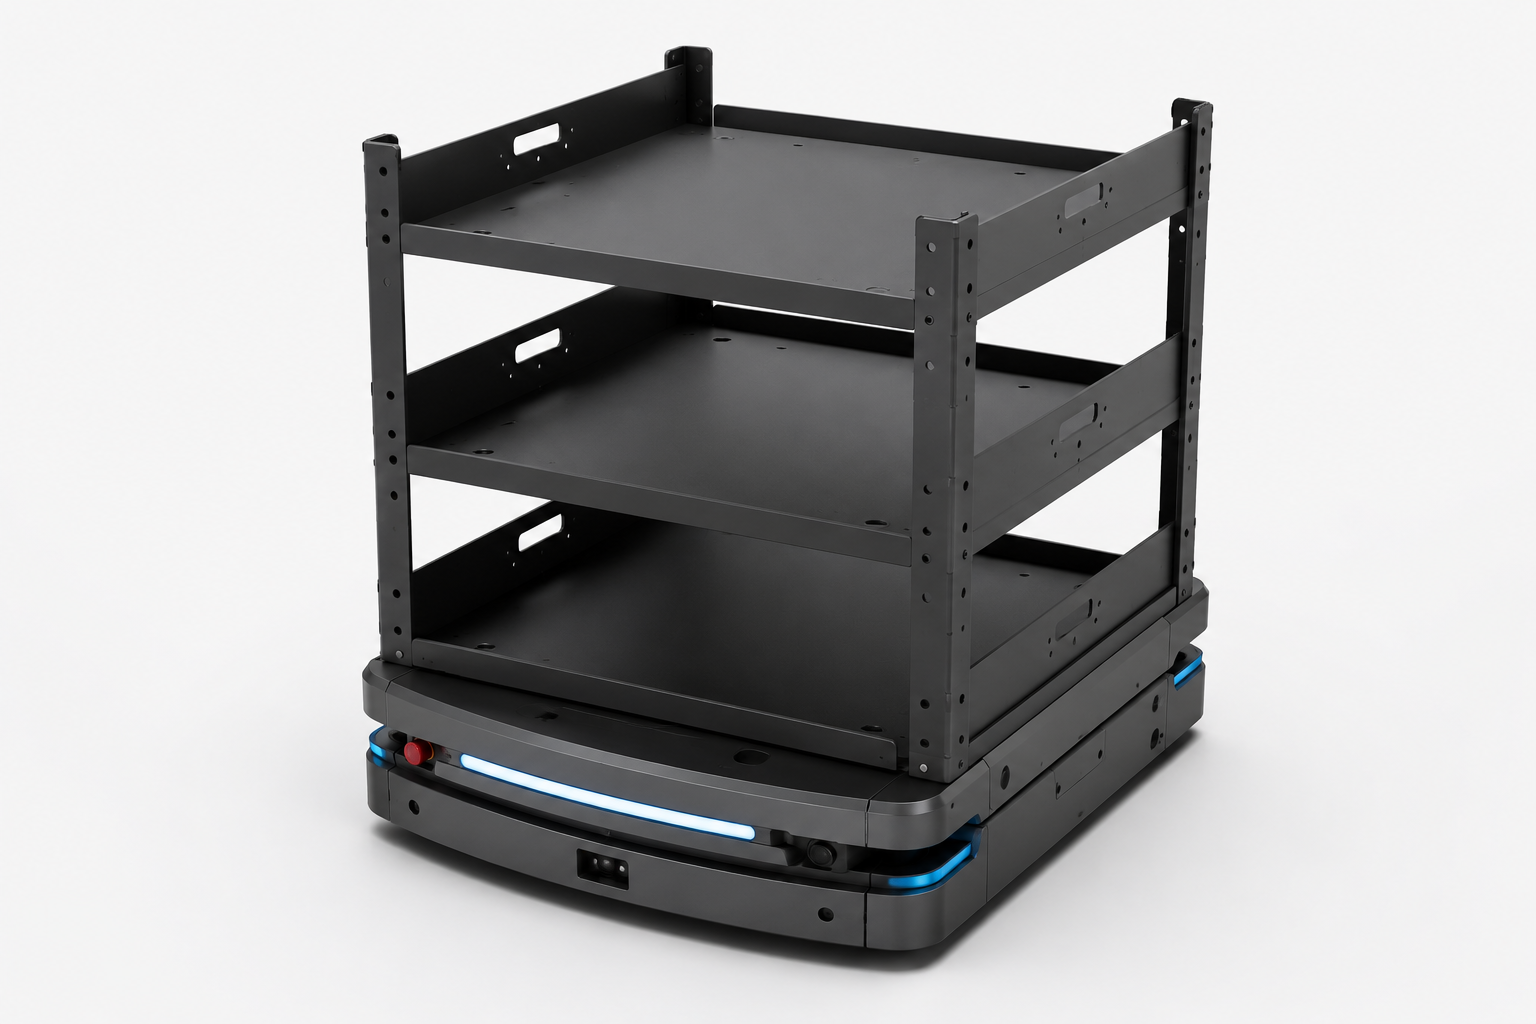
Stackable Payload Module
flexible hardware expansion.
Use Cases

Indoor Navigation & SLAM Research

Vision Based Alignment, following and docking

Marker-driven point to point Autonomy

Rapid Prototyping Of indoor AMR behaviours
Gallery